Module A65% of Course Time
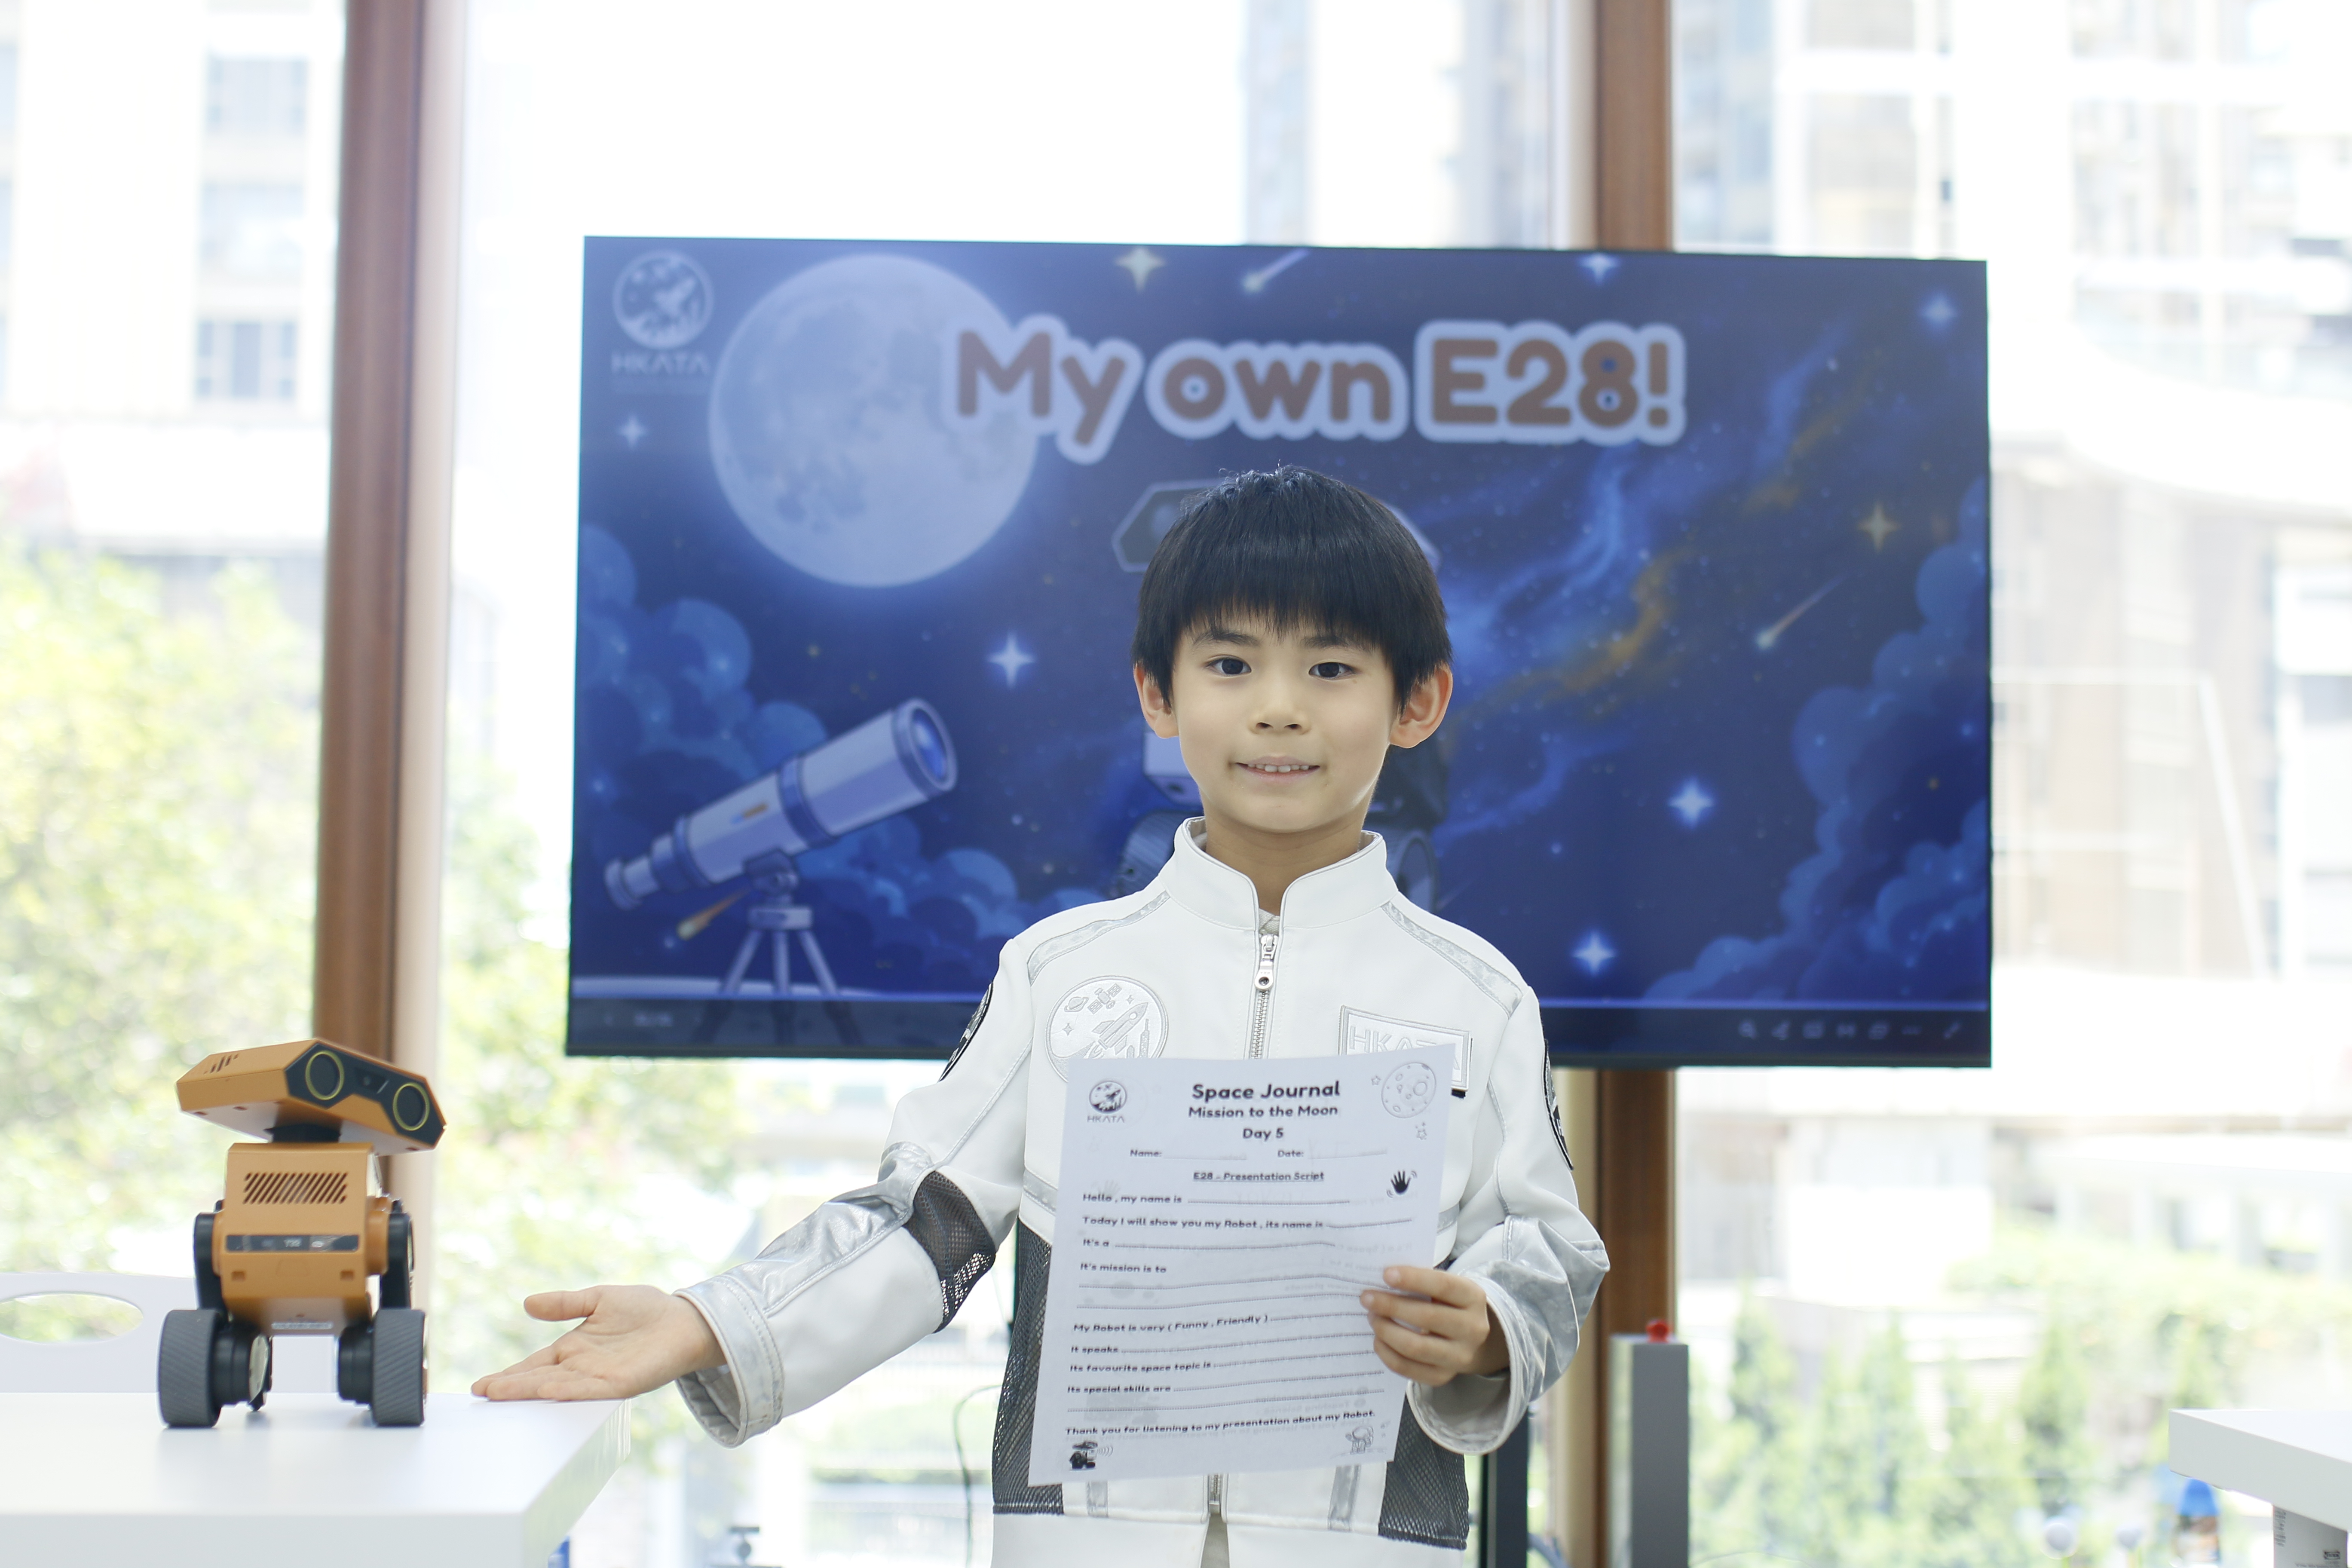
The E-28 Space AI Robot
Students build and program a bipedal robot from scratch, moving through the machine's sensing, navigation, and mobility systems.
The Brain & Senses (Head)
Hardware
4-mic array, camera module, 2 servos
Knowledge
360-degree sound source localization, AI target detection, and Large Language Model-powered natural voice conversation.
The Core & Navigation (Body)
Hardware
6-Axis IMU, 3-Axis Magnetometer, 2 Infrared TOF modules
Knowledge
Angular velocity for self-balancing, absolute positioning, and automated obstacle avoidance logic.
The Mobility System (Legs - Focus for 5-Day)
Hardware
2 structural servos, 2 brushless DC motors
Knowledge
Implementing the PID algorithm to achieve bipedal self-balancing and controlled forward motion.